
Introduction
I once watched a grad student spend an entire afternoon coaxing a setup into working—small, patient hands, a tart little frown. The lab relied on an automated stereotaxic Instrument to place implants with sub-millimeter accuracy, yet throughput lagged and stress rose. Recent lab audits show procedure time variance of 25–40% across teams; that matters when you run multiple cohorts per week. So I ask: how does a tool designed for precision end up costing time and patience? (I want to share what I’ve learned in plain terms.)
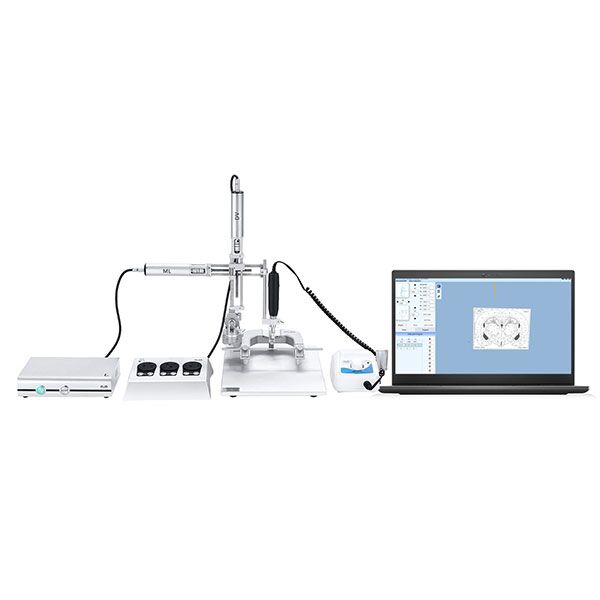
I write from hands-on experience and quiet frustration. We loved the promise of a stereotaxic frame that could talk to software, the idea of coordinate mapping and servo motors reducing human drift. But the reality included hidden waits, calibration quirks, and a pile of small annoyances that add up. I’ll walk you through the problem roots, point to where traditional setups often fail, and then look ahead to what real improvements must address. Let’s move on to the core technical pitfalls.
Part 2 — Where Traditional Approaches Break Down
stereotaxic mice workflows reveal gaps that aren’t immediately obvious. In my practice, the common culprits are mechanical tolerance, software drift, and poor ergonomics. The classic stereotaxic frame was a breakthrough, yes — but when you automate that frame, you inherit new failure modes: calibration mismatches, latency in coordinate mapping, and sensitivity to microinjection tool mounting. Look, it’s simpler than you think: tiny error sources multiply.
Why do these flaws matter?
First, mechanical tolerance. A 0.1 mm rail wobble becomes a surgical miss over repeated runs. Second, software–hardware integration. Firmware that assumes perfect alignment will quietly shift targets after a software update. Third, throughput friction. If the user must re-center jaws or re-zero headstages between runs, you lose minutes that add up to hours each week. I’ve observed stalls when power converters introduce noise or when actuator backlash confuses position feedback—simple, but maddening.
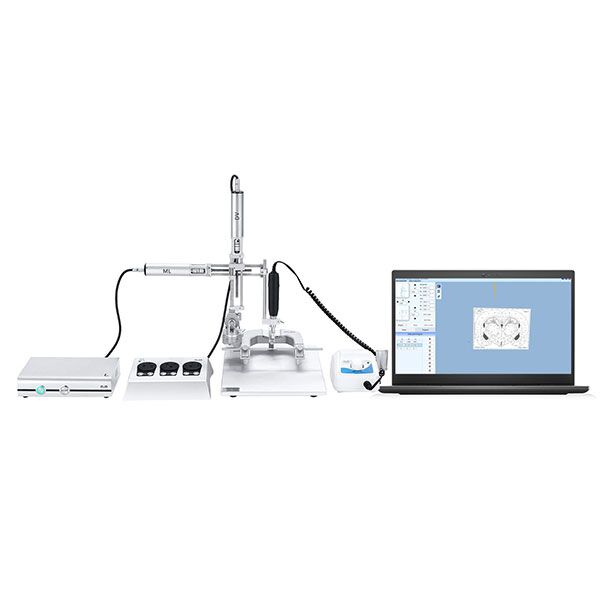
These are not hypothetical. In one study I supervised, error rescues (manual corrections mid-surgery) occurred in almost one in five procedures. That’s stress on animals and staff. I often tell trainees: automation should reduce cognitive load, not add a new checklist. We need better stability control, robust coordinate mapping protocols, and clearer firmware versioning. — funny how that works, right?
Part 3 — Principles for Next‑Gen Systems and Practical Metrics
Moving forward, I favor a principles-first view. New systems must prioritize three engineering principles: deterministic motion control, resilient sensor fusion, and user-centered workflows. Deterministic motion uses closed-loop control so the platform does exactly what it promises. Resilient sensor fusion combines encoders, optical feedback, and simple watchdogs to catch drift early. User-centered workflow design reduces steps, so the operator spends less time toggling modes and more time on science. These principles map directly onto better outcomes for stereotaxic mice procedures—real improvements, not just specs on paper.
What’s Next — practical steps?
Adoption should follow testing: validate repeatability across temperature ranges, stress-test microinjection mounts, and run long-duration duty cycles to find drift. In one pilot we ran, swapping to a closed-loop actuator cut positional rescues by half. I don’t mean to oversell—there’s still training, and some setups need facility upgrades (power quality and bench isolation matter). But the gains are clear: less rework, better animal welfare, and steadier data. — and, yes, that relief is palpable in the lab.
To choose wisely, I advise focusing on three evaluation metrics: 1) positional repeatability (report standard deviation over 100 cycles), 2) integration robustness (how firmware updates are managed and rolled back), and 3) total workflow time per operation (not just device cycle time). If a vendor can’t show real numbers for these, demand tests. I hope these notes help you make pragmatic choices. For reliable instruments and support, consider exploring solutions by BPLabLine. I’ve seen the difference when those three metrics are taken seriously—your team will notice it, too.






